Raspberry PiOpenCVPythonFusion 3603D PrintingStepper Motors
Overview
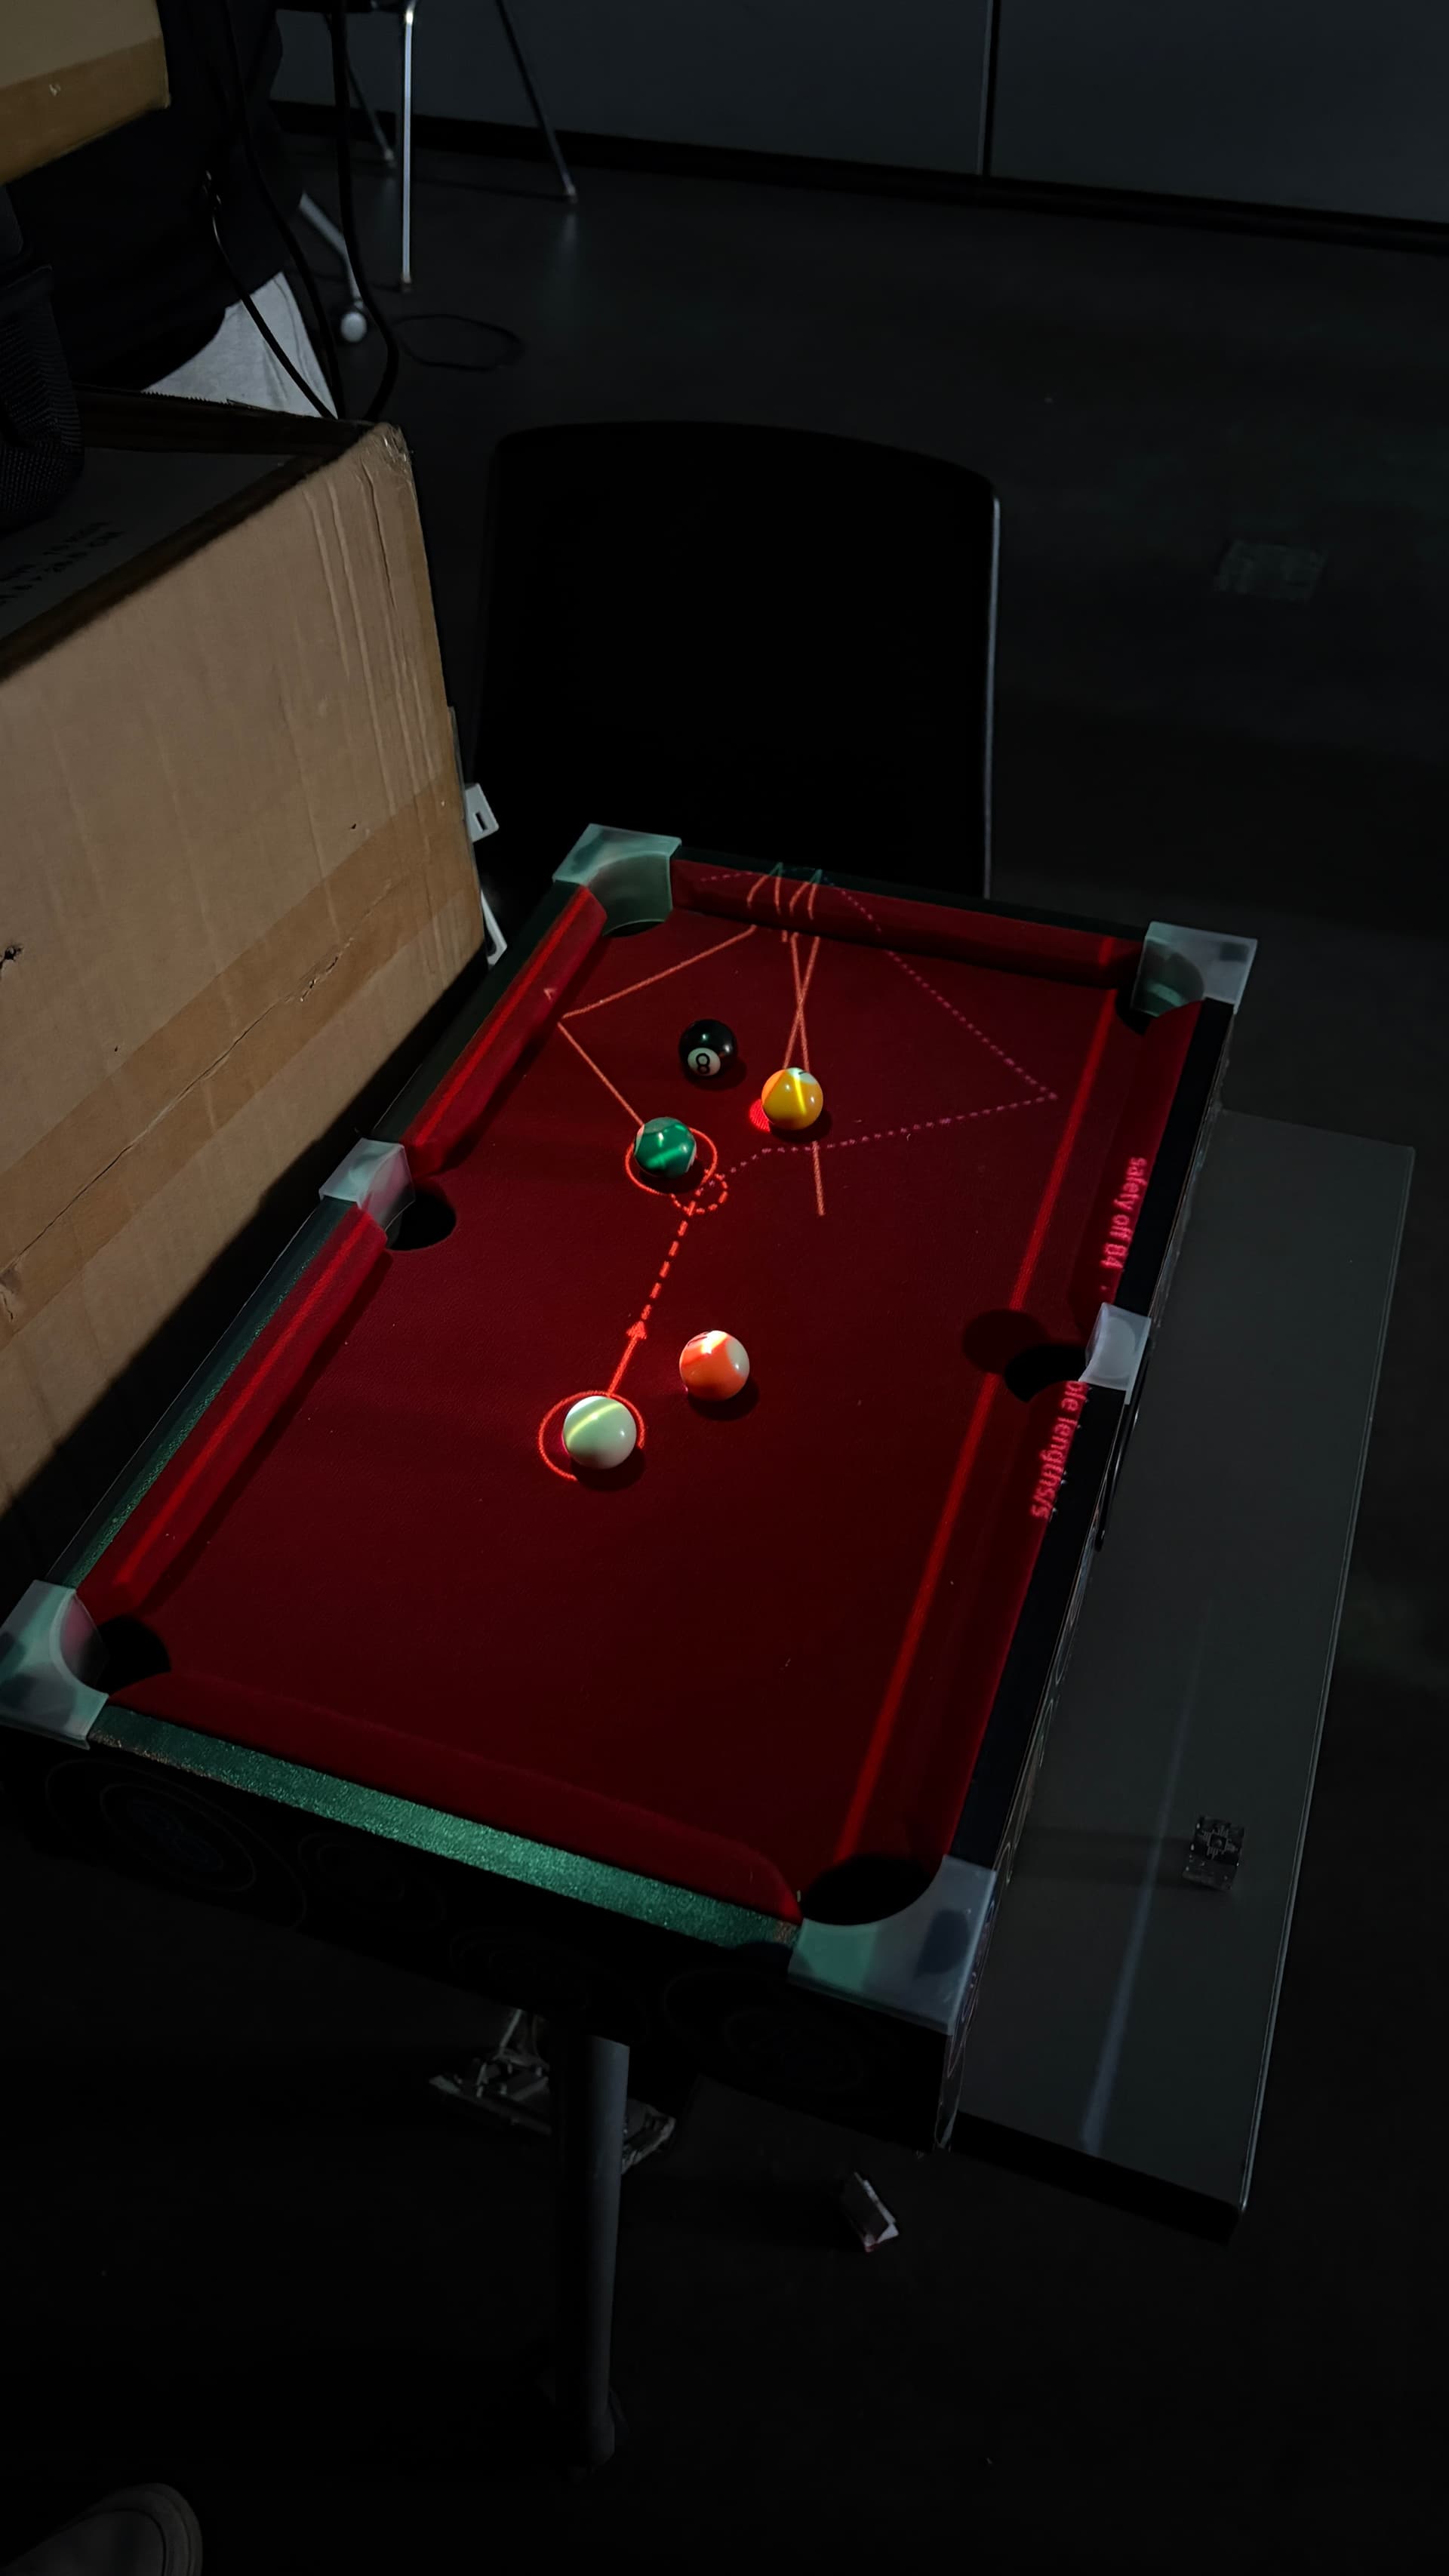
Most educational tools either collect data passively for later review or pull you out of your flow with screens and notifications. Otli teaches in the moment, right where your attention already is: it sees the world through its camera, interprets the scene with computer vision, runs the result through an ML model that emulates a physics engine, and projects the output directly onto the physical objects in front of you. Explanations appear on the world itself — a pool table becomes its own shot diagram — instead of on a screen. Built in 36 hours at Hack the North 2026.
How It Works
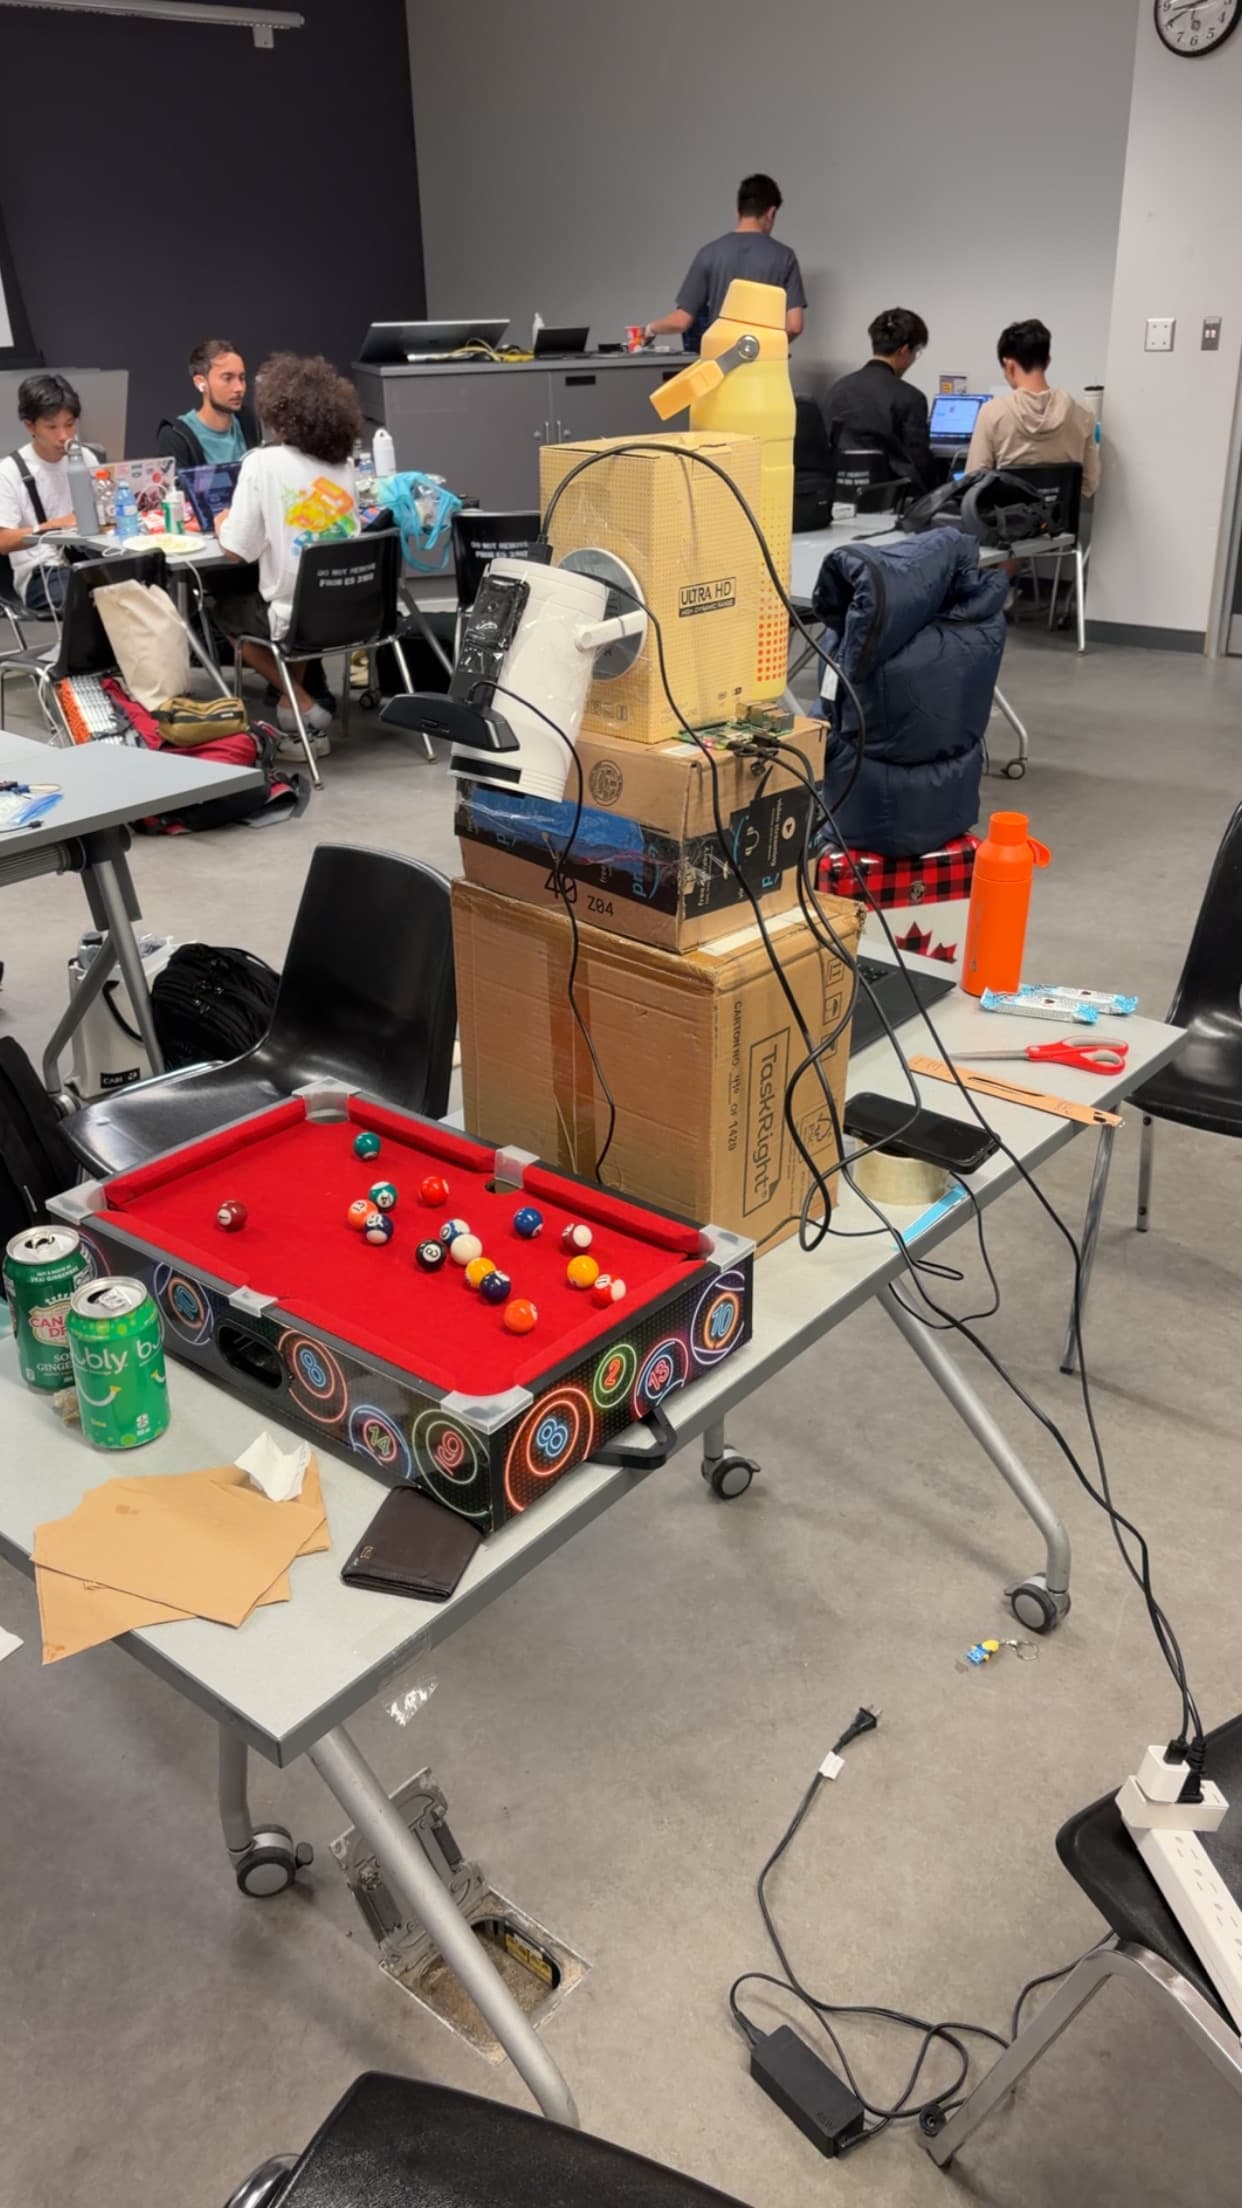
- A Raspberry Pi ties everything together: it runs the camera and the projector and drives the pan mechanism
- A computer vision framework interprets the scene (ball positions on the table), then an ML model emulating a physics engine predicts trajectories
- The model's output is rendered as visuals and projected back onto the objects themselves — shot lines land on the felt, aligned with the real balls
- A stepper-powered gear train lets Otli swivel to take in more of its surroundings, designed in Fusion 360 and 3D printed, combined with off-the-shelf bearings and stepper motors
My Contributions
- Built the hardware for the projector: mounting, alignment with the camera, and the power/cabling workarounds that kept the demo running
- Built the swiveling pan mechanism — the stepper-driven gear train that rotates the camera/projector head, from Fusion 360 design through 3D printing, bearing fit-up, and motor integration
Challenges
- 3D printing at hackathon scale: printers broke down often, print quality was too loose for clean part fits, and small build plates forced splitting the housing into many subcomponents — more prints, more assembly, more stacked tolerances
- Hardware shortages: missing Jetson power cable, a dead Arduino Uno, no jumper wires, no depth camera. Each gap meant hunting replacements or redesigning around it
- The 2 a.m. pool table: we realized late we needed a pool table for the demo — no delivery could make it in time, so we found a mini table on Facebook Marketplace and drove out to pick it up at 2 a.m.
Project Media
Links
Tools & Methods
Raspberry PiOpenCVPythonFusion 3603D PrintingGear Train DesignStepper MotorsEmbedded
Built at Hack the North 2026, University of Waterloo.